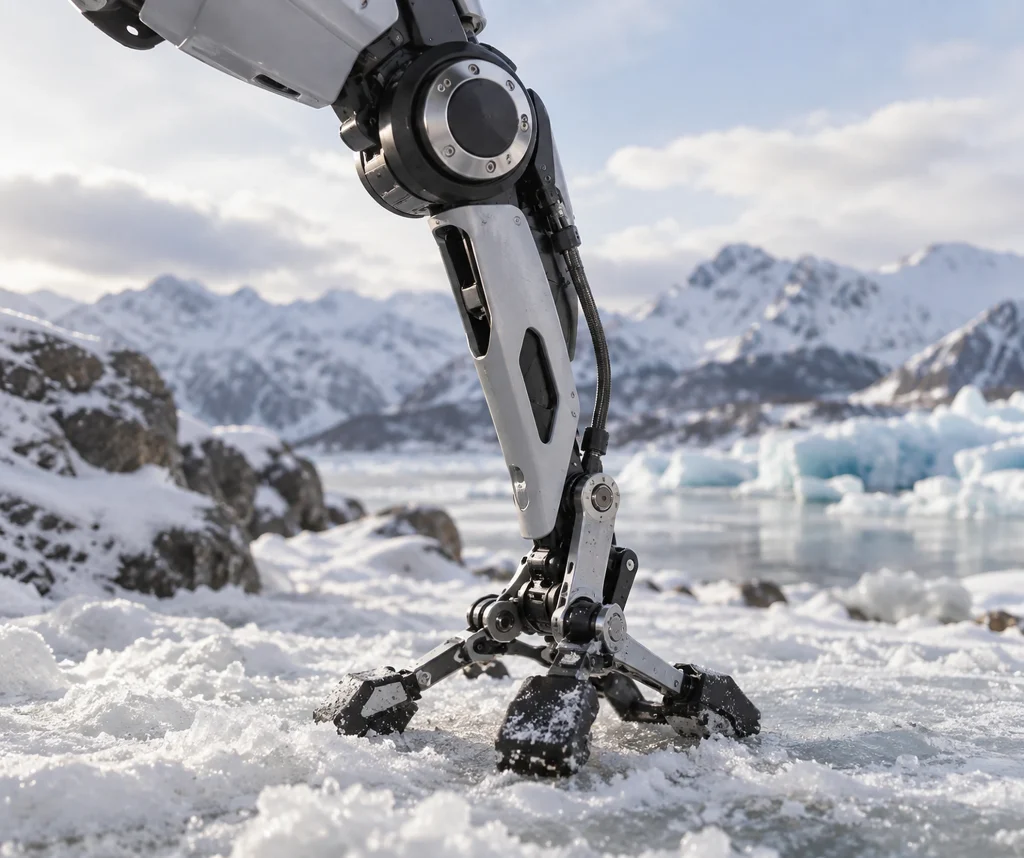
University of Toronto engineering students have developed a one-legged hopping robot propelled by the thrust of four propellers. The rotating foot with protrusions on its spring-loaded leg adapts to surfaces ranging from soft sand to hard ice.
While the pointed tip used in initial trials failed, the new design enables the robot to overcome obstacles and travel through the Canadian winter.
Why it matters
This study shows that a one-legged robot depends not only on its hopping motion but also on a foot design that adapts to ground conditions. In this respect, the project demonstrates the role of mechanical adaptation in designing mobile robots that transition between soft and hard surfaces. For the students, replacing the previous pointed-tip solution provides a concrete example of how the failure of an initial idea is part of the robot development process. However, the available information does not explain how long the robot can operate steadily on different surfaces, its speed, or its real-world applications; the scope of its performance can therefore currently be assessed only in terms of the variety of surfaces used in the trials, while the limits of its applications remain unclear.